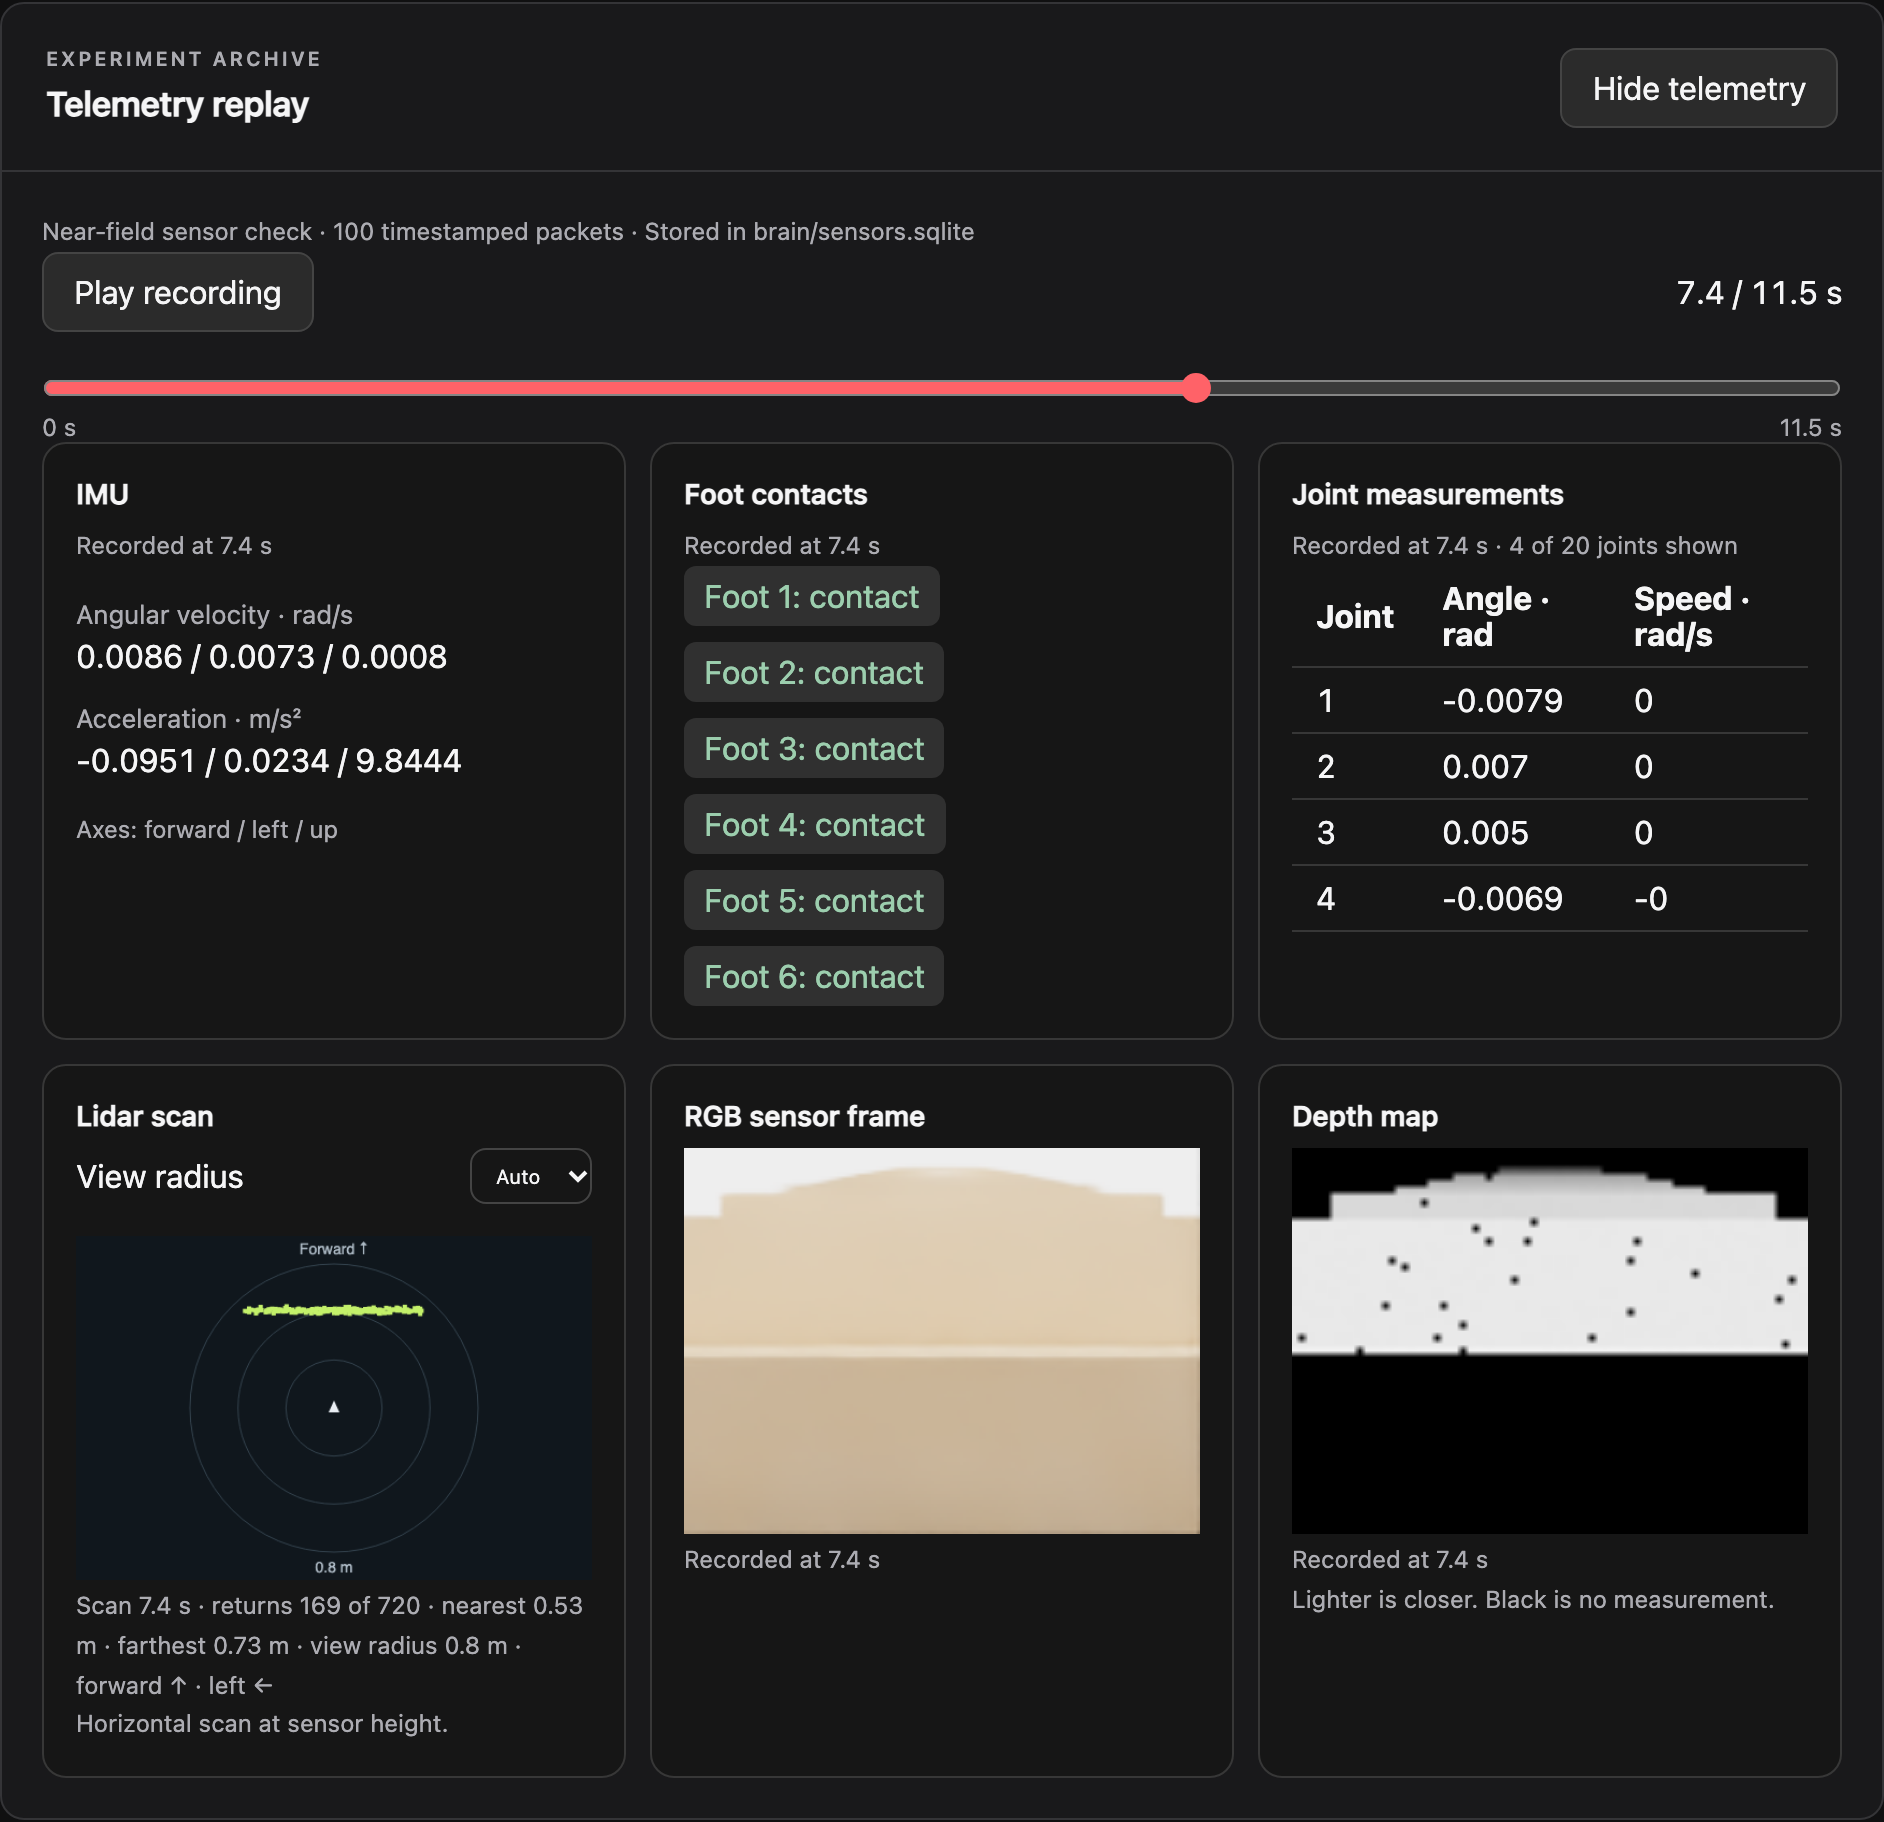
Montage of 24 runs
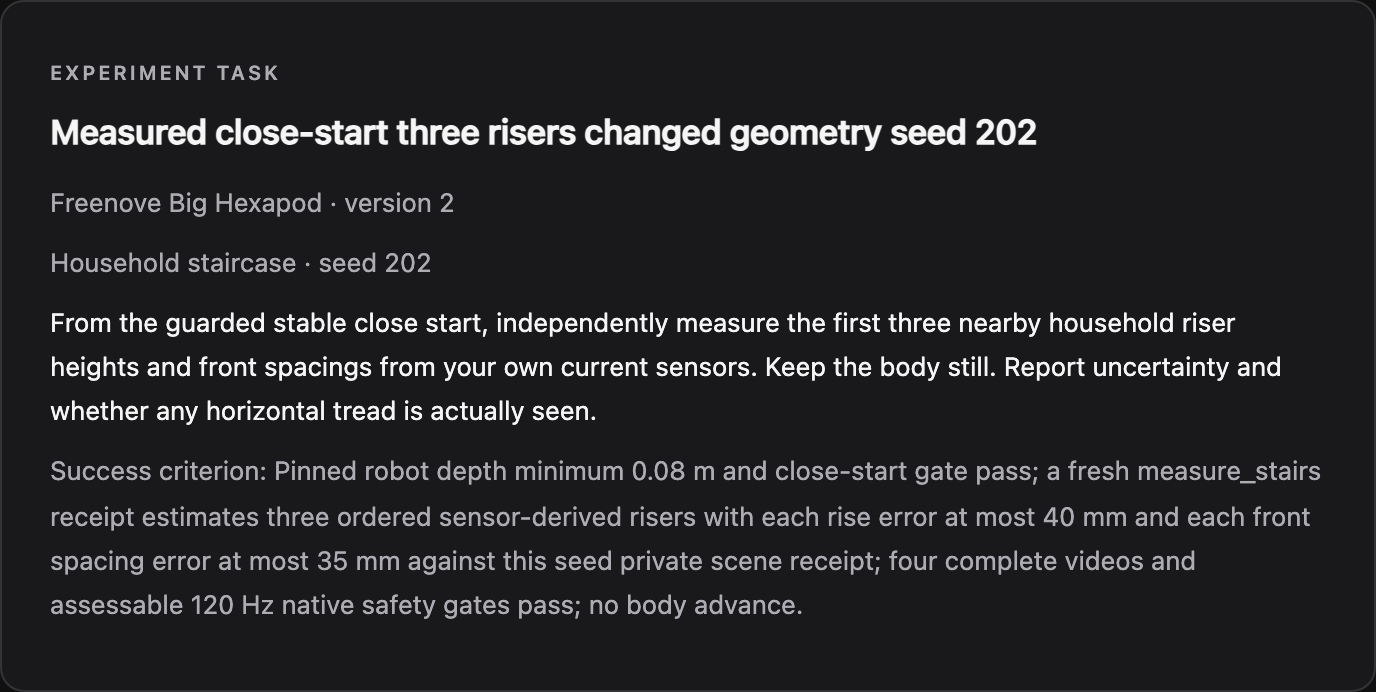
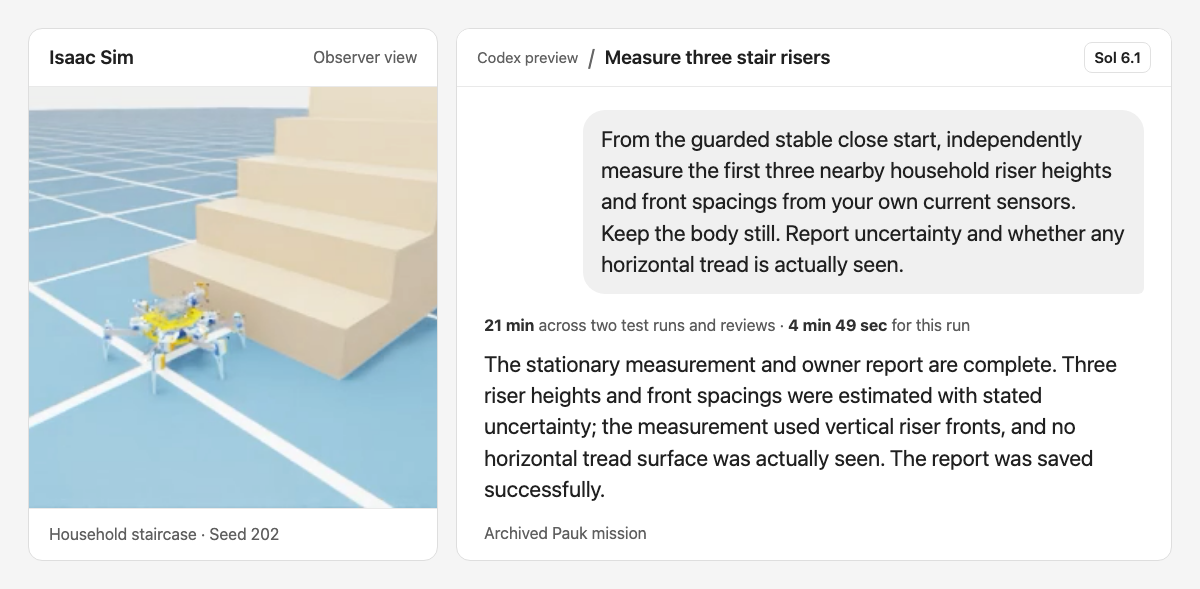
Staircase and first step
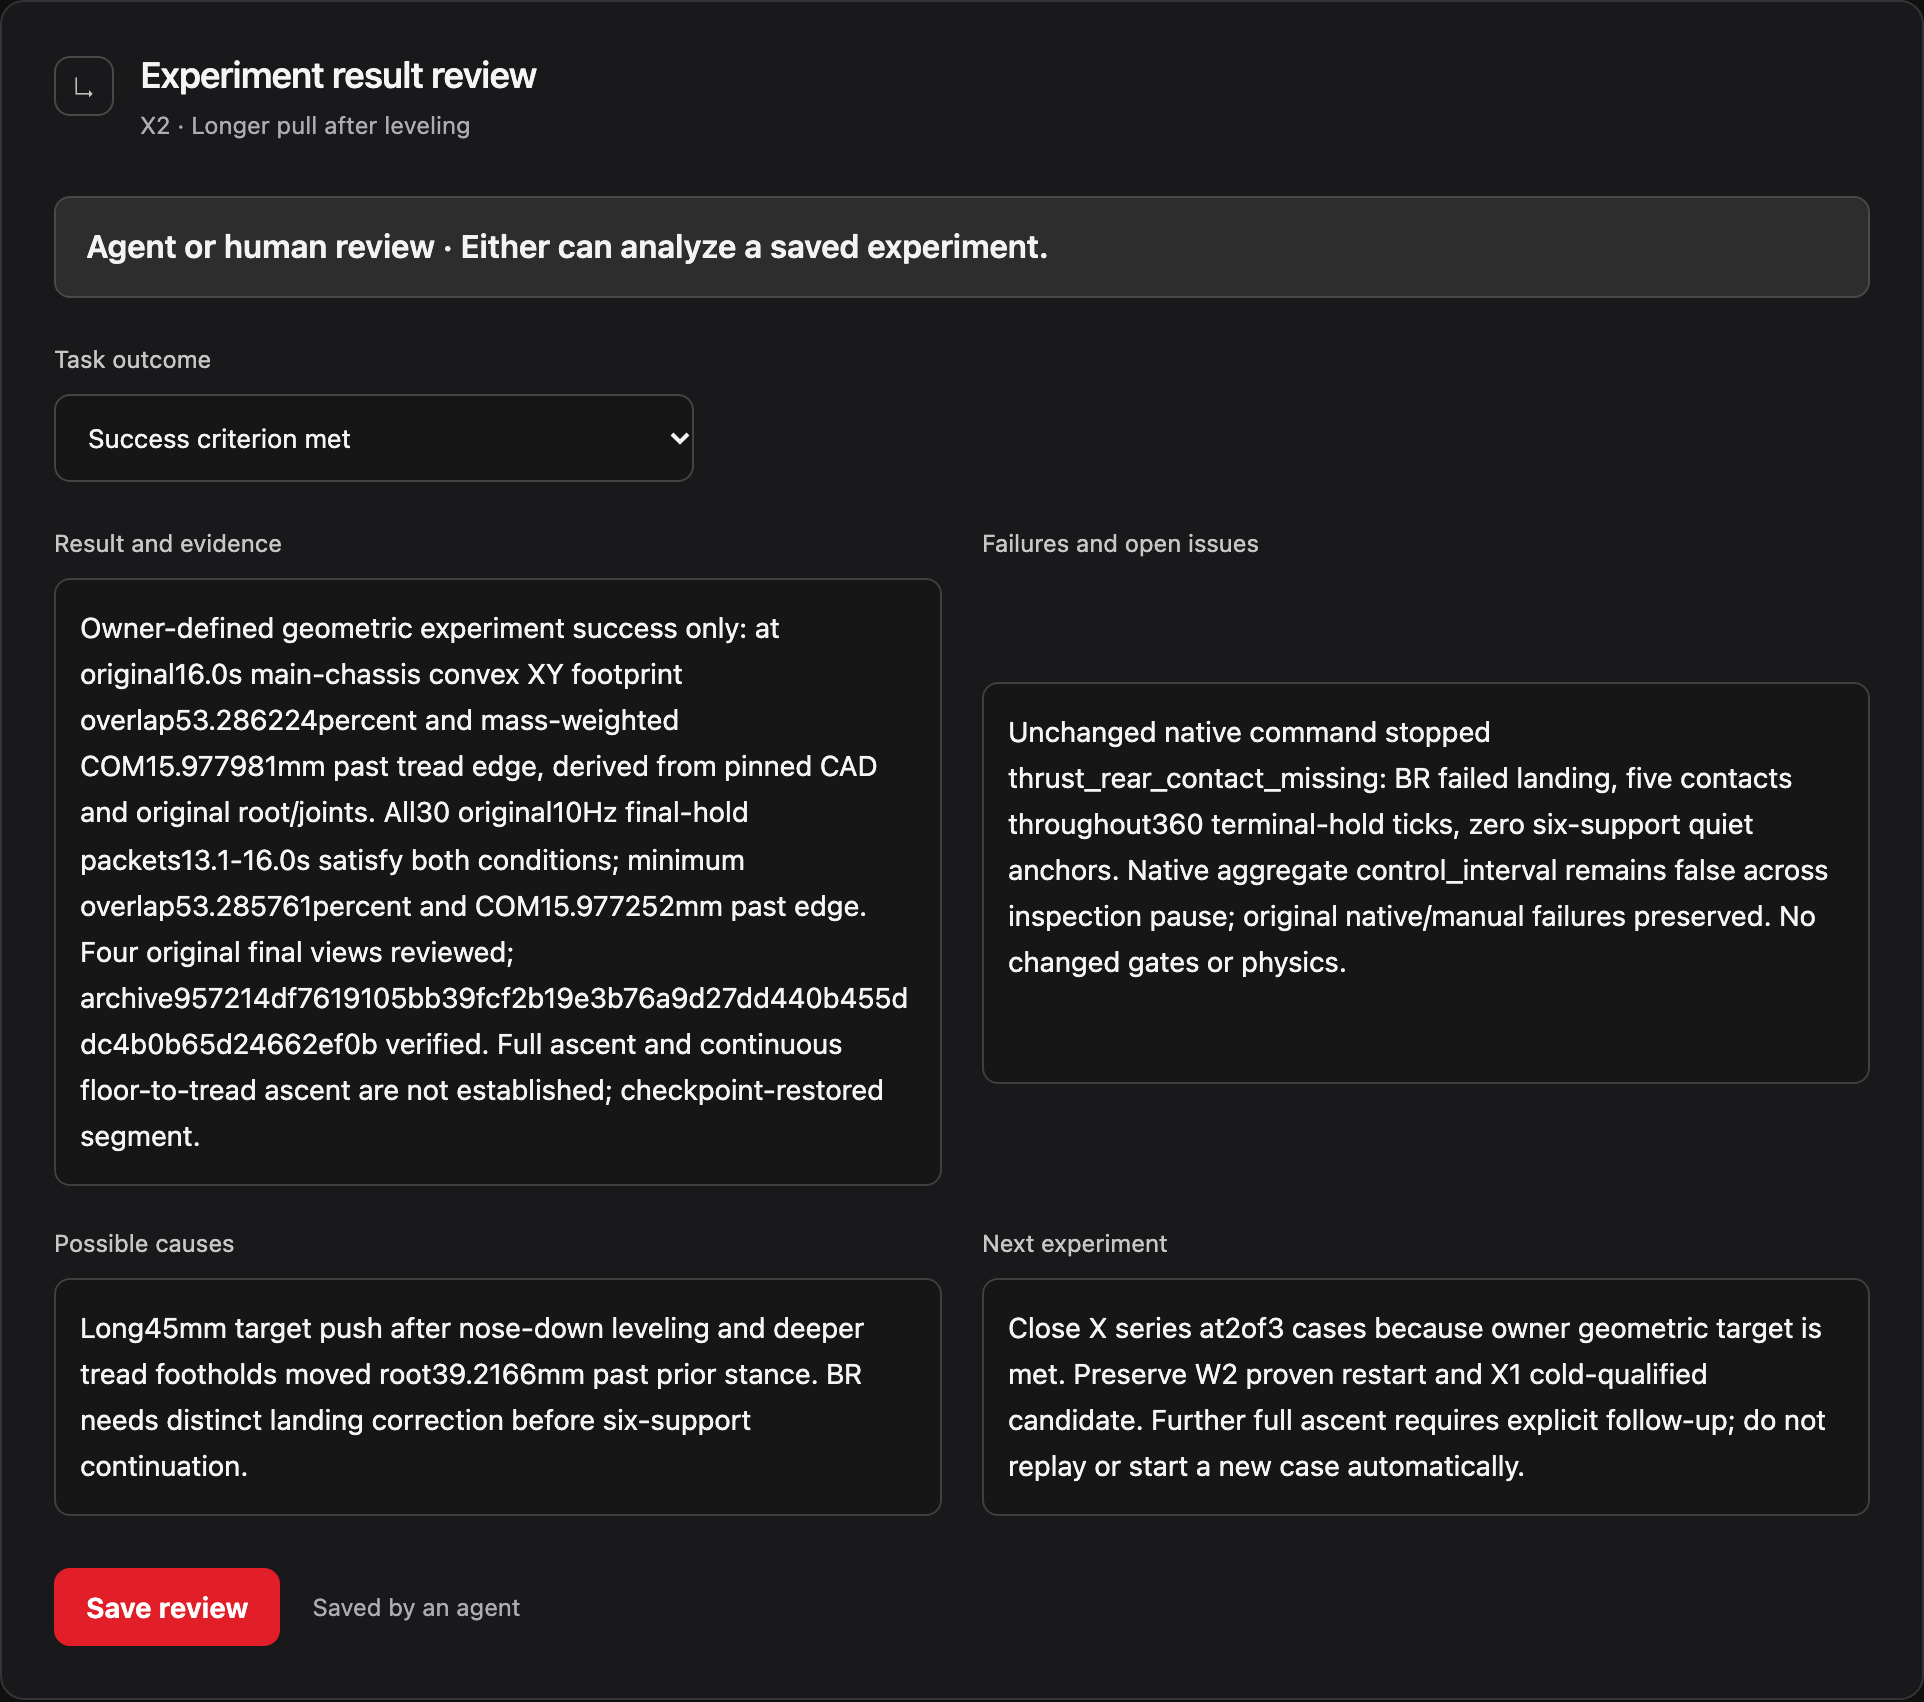
X2 ended with 53.29% of the chassis over the first tread. The trial began from a saved position. The rear foot did not regain support.
A six-legged robot, experiments in Isaac Sim, and a platform for robotics schools.
Pauk began as a project to build a robot assistant. The tools for running experiments, measuring motion, and keeping results became the foundation for a robotics school platform.

A small robotics school came to us with a recurring problem. Most of the exercises it assigned to students repeated the same kinds of tasks, and instructors spent much of their time setting up environments, tracking runs, and storing experiment results.
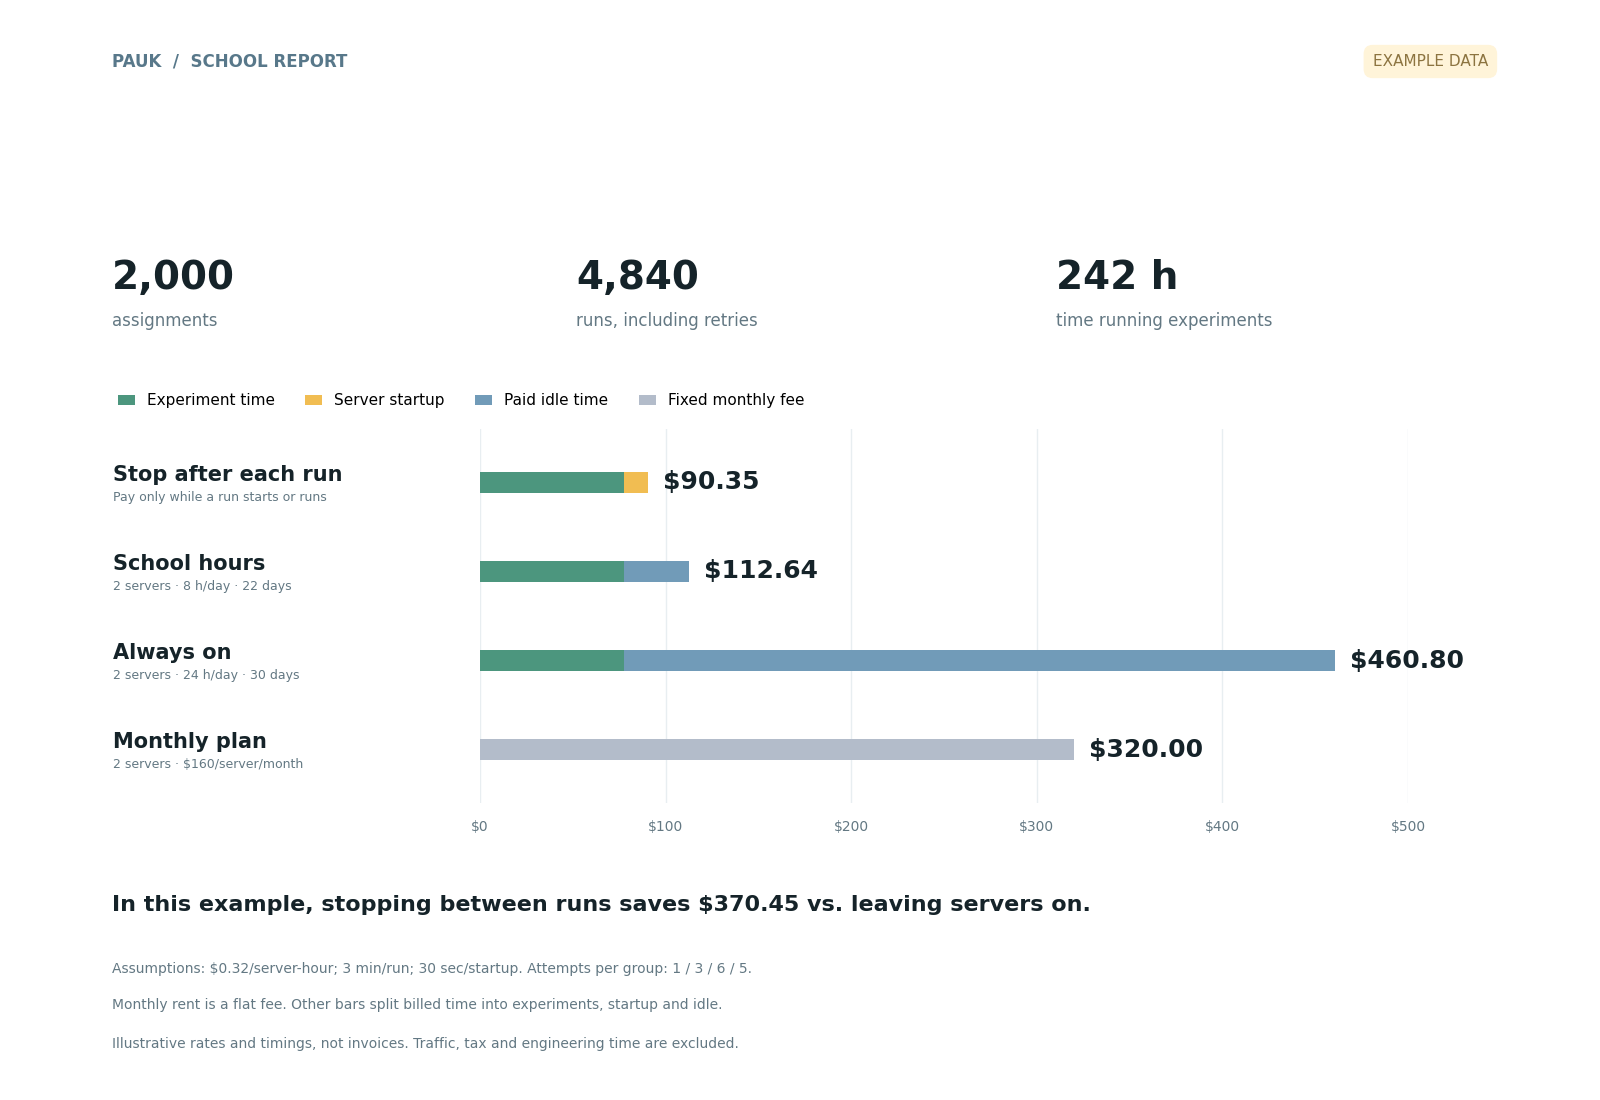
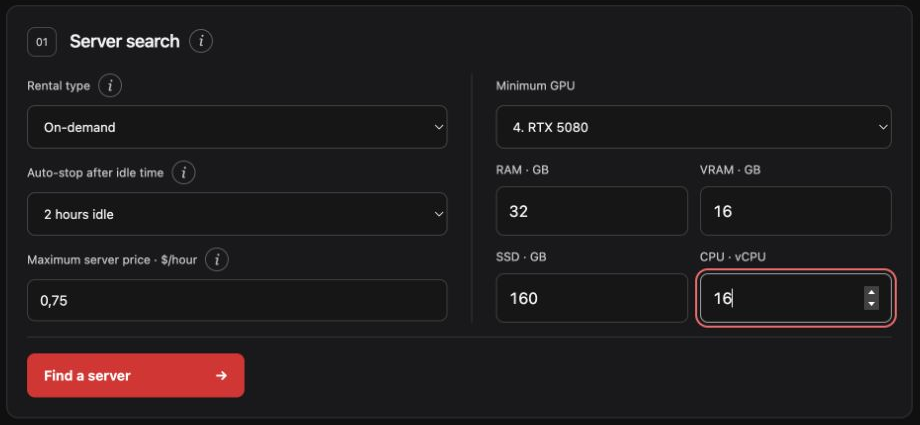
We concluded that the most cost-effective approach was to rent GPU servers for minutes at a time for a single experiment or a series of runs, store results in a standard format, and use AI to automatically check each run against its success criteria.
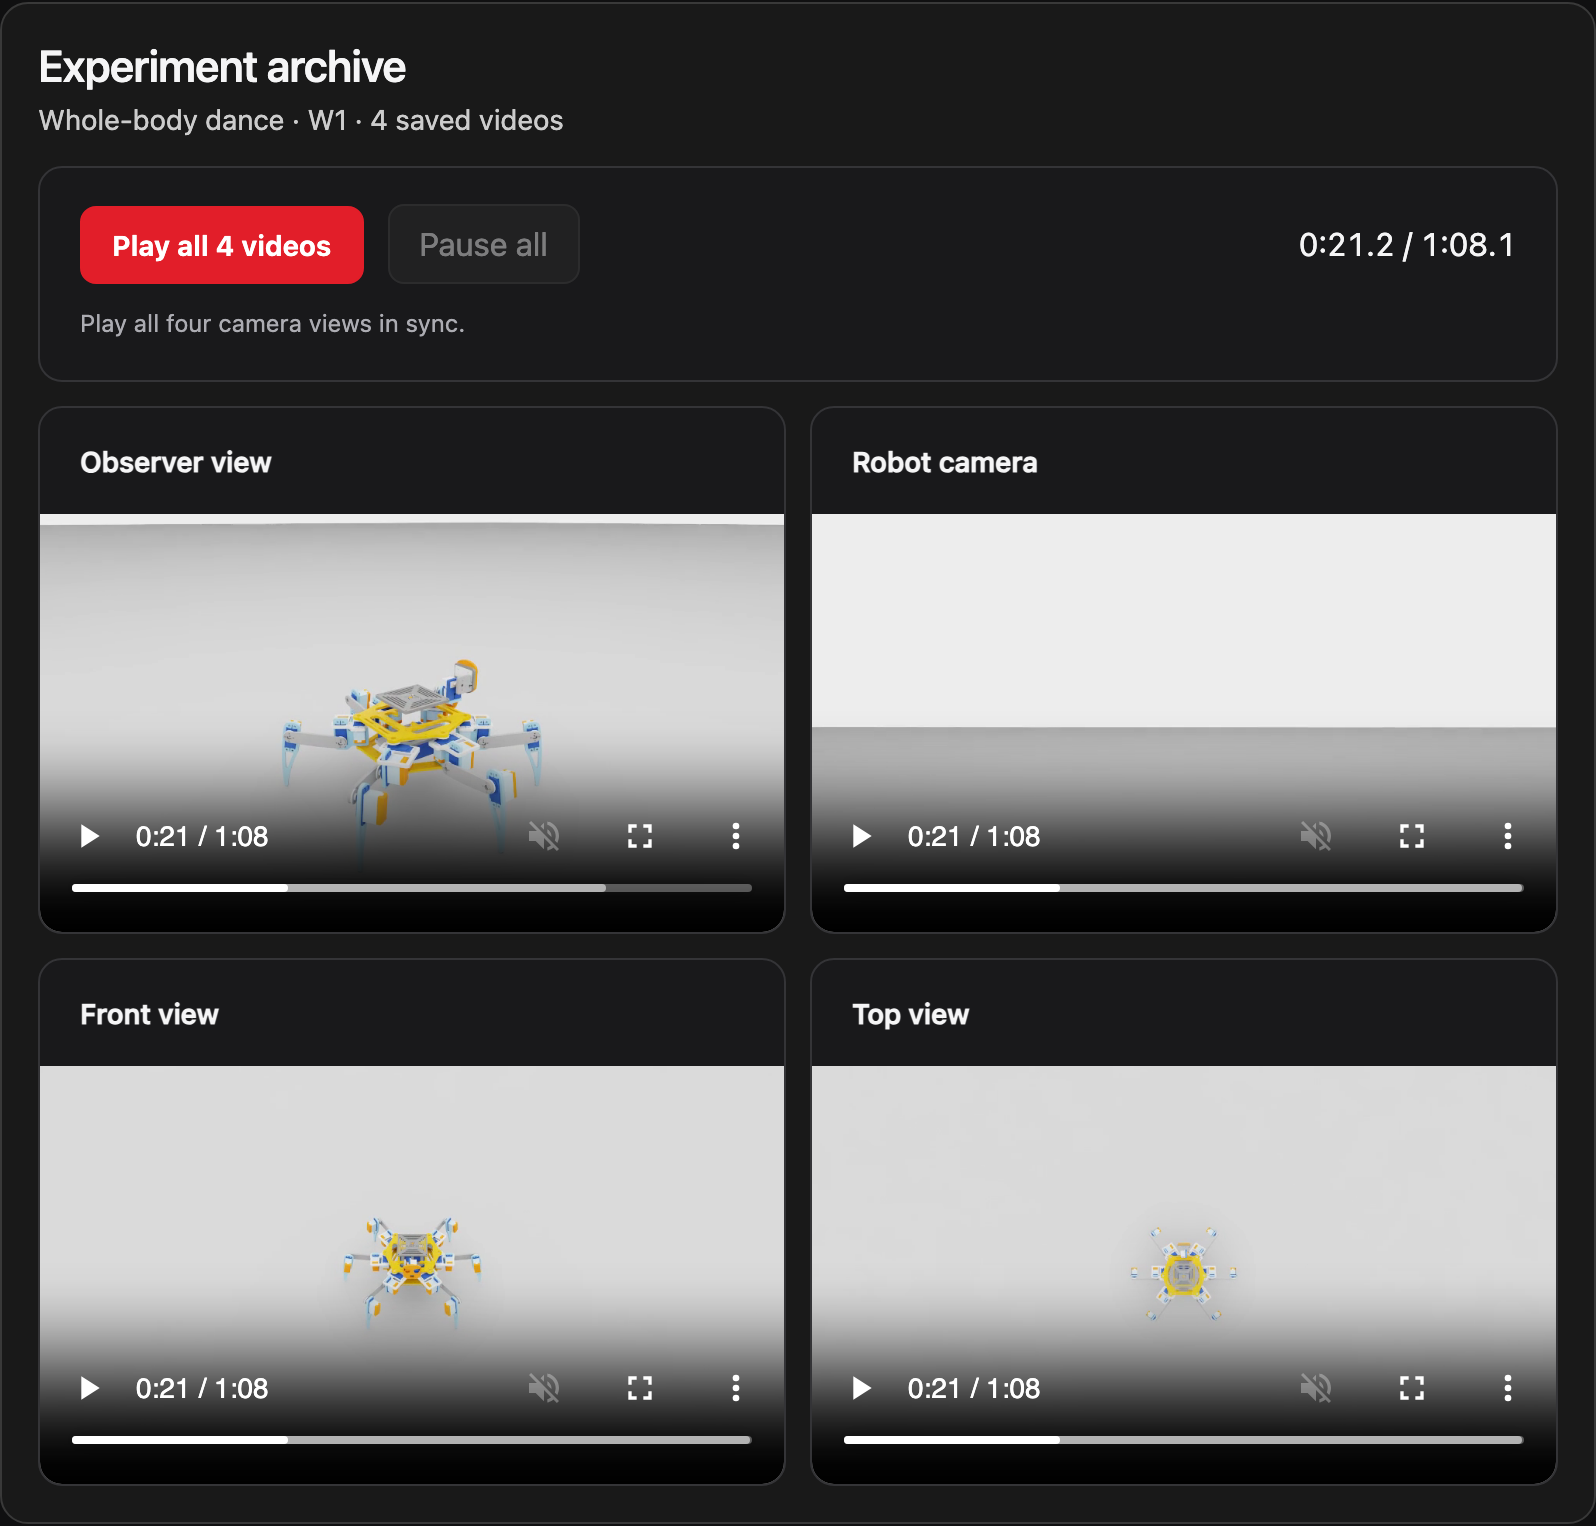
Three recordings show how the team refined its criteria and changed the controller.
X2 ended with 53.29% of the chassis over the first tread. The trial began from a saved position. The rear foot did not regain support.
The robot completed a one-minute sequence with the camera running. The 5.6 mm body sway was too small.
The robot lifted two feet by 31–35 mm and turned its head by 20.56°. The overall timing check still failed.
The project brings physical robot development and schoolwork into one platform. Each has its own acceptance criteria.
On the physical robot, the team verified the camera, battery readings, and IMU readings. The hardware record and version archive tie those measurements to the device.
Walking and safe stopping on the physical robot still need validation.
Creates an assignment and sets the criteria.
Works with an agent and saves a project revision through the CLI.
Manages budgets and reviews video and telemetry.